Oscillations
Contents: 5 sections
Cambridge International AS & A Level Physics 9702 · A Level
All three subtopics here are printed under "A Level subject content" in the 9702 syllabus, and every objective carries the tier "A Level". None of it is AS. It is examined on Paper 4. Angular frequency, ω, is the same quantity as the angular speed of topic 12, and every angle in this topic is in radians.
17.1 Simple harmonic oscillations
The vocabulary
- Displacement x: the distance of the oscillating object from its equilibrium position, in a stated direction. It is a vector, so it is negative on the other side of equilibrium.
- Amplitude x₀: the maximum displacement from the equilibrium position. It is measured from the middle, not from one extreme to the other: a pendulum swinging through a total of 8.0 cm has an amplitude of 4.0 cm.
- Period T: the time for one complete oscillation, in s.
- Frequency f: the number of complete oscillations per unit time, in Hz, with f = 1/T.
- Angular frequency ω: the frequency expressed as an angle per unit time, in rad s⁻¹, with ω = 2πf.
- Phase difference: how far one oscillation is ahead of or behind another, as a fraction of a cycle expressed as an angle. A whole cycle is 2π rad, so a quarter of a cycle is π/2 rad and half a cycle is π rad. For two oscillations of the same period, phase difference = 2π × Δt / T, where Δt is the time between corresponding points.
The period in terms of frequency and of angular frequency:
T = 1 / f = 2π / ω
Worked example 1. A mass on a spring makes 20 complete oscillations in 12.0 s. Find the period, the frequency and the angular frequency.
T = 12.0 / 20 = 0.60 s
f = 1 / 0.60 = 1.667, so f = 1.67 Hz
ω = 2π / T = 2π / 0.60 = 10.5 rad s⁻¹
Timing many oscillations and dividing is how a period is measured in practice: it shrinks the effect of your reaction time on each start and stop.
Worked example 2. Two pendulums each have a period of 2.0 s. Pendulum B passes through its equilibrium position, moving the same way, 0.50 s after pendulum A. Find the phase difference.
phase difference = 2π × 0.50 / 2.0 = π/2 rad
so B lags A by π/2 rad, a quarter of a cycle. The trap: giving the answer as 0.25. A phase difference is an angle, in radians (or degrees, 90°).
The defining condition
Simple harmonic motion occurs when the acceleration is proportional to the displacement from a fixed point and is directed in the opposite direction to the displacement, that is, always towards the fixed point.
a = −ω²x
- a is the acceleration in m s⁻²
- x is the displacement from the equilibrium position in m
- ω is the angular frequency in rad s⁻¹
The minus sign is the whole of the physics. It says the acceleration always points back towards equilibrium, and the further the object is displaced, the harder it is pulled back. That restoring tendency is what makes the motion repeat.
Two consequences follow at once, and both are examined:
- A graph of a against x is a straight line through the origin with a negative gradient, and the gradient is −ω². To find the period from such a graph, read the gradient, take the square root of its magnitude to get ω, then use T = 2π/ω.
- The period does not depend on the amplitude. A pendulum clock keeps time as its swing dies away for this reason.
Worked example 3. A graph of acceleration against displacement for an oscillating object is a straight line through the origin with gradient −250 s⁻². Find the period.
ω² = 250, so ω = √250 = 15.81 rad s⁻¹
T = 2π / ω = 2π / 15.81 = 0.397 s
The trap: forgetting to take the square root, or trying to take the square root of −250.
The equations of motion
The syllabus gives x = x₀ sin ωt as the solution of a = −ω²x. This form starts the clock when the object is at equilibrium, moving in the positive direction:
x = x₀ sin ωt
Its velocity is
v = v₀ cos ωt
where the maximum speed is v₀ = ωx₀, reached as the object passes through equilibrium.
If instead the clock starts when the object is released from maximum displacement, the cosine form fits: x = x₀ cos ωt. Read the question to find where t = 0 is. Either way ωt is an angle in radians, so set your calculator to radians.
The equation that links speed and position without time is often the most useful:
v = ±ω√(x₀² − x²)
The ± is there because the object passes each position twice per cycle, once in each direction. Reading off the special cases:
- at x = 0 (equilibrium), v = ±ωx₀ = ±v₀, the maximum speed
- at x = ±x₀ (the extremes), v = 0: the object is momentarily at rest
Worked example 4. A mass oscillates in simple harmonic motion with amplitude 5.0 cm and period 0.40 s. Find (a) the maximum speed, (b) the speed at a displacement of 3.0 cm, (c) the maximum acceleration.
ω = 2π / 0.40 = 15.71 rad s⁻¹
(a) v₀ = ωx₀ = 15.71 × 0.050 = 0.7855, so v₀ = 0.79 m s⁻¹
(b) v = ω√(x₀² − x²), and x₀² − x² = 0.050² − 0.030² = 0.0016, whose square root is 0.040 m:
v = 15.71 × 0.040 = 0.6284, so v = 0.63 m s⁻¹
(c) a = ω²x₀ = 15.71² × 0.050 = 12.34, so the maximum acceleration is 12.3 m s⁻², at the extremes, where the displacement is largest.
The trap in (b): writing √(x₀ − x)² = x₀ − x, which gives 0.020 m and a speed half the true value.
Worked example 5. For the same oscillator, starting from equilibrium at t = 0, find the displacement at t = 0.050 s.
ωt = 2π × 0.050 / 0.40 = π/4 rad, which is 0.785 rad
x = x₀ sin ωt = 5.0 × sin(0.785 rad) = 5.0 × 0.7071 = 3.54
so x = 3.5 cm. With the calculator in degree mode, sin(0.785°) gives 0.069 cm, a nonsense answer that is easy to miss.
Reading the graphs
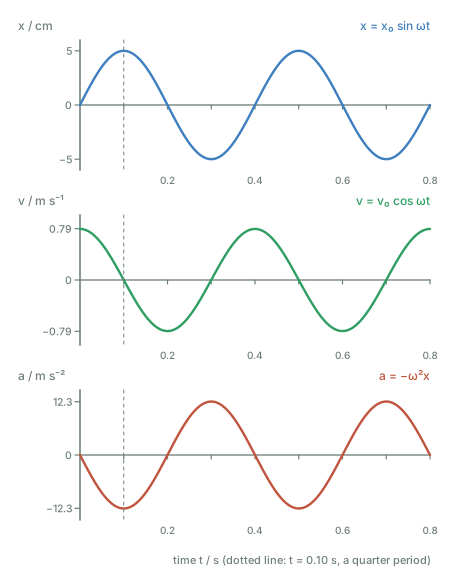
For an oscillator that starts at equilibrium, so that x = x₀ sin ωt:
| Quantity | Shape | Largest magnitude | Zero |
|---|---|---|---|
| Displacement x | sine | at the extremes | at equilibrium |
| Velocity v | cosine | at equilibrium | at the extremes |
| Acceleration a | negative sine | at the extremes | at equilibrium |
Three relationships hold whichever starting point is used, and they are what graph questions test:
- Velocity is the gradient of the displacement-time graph. Where x is at a peak, the gradient is zero, so v = 0.
- Acceleration is the gradient of the velocity-time graph, and since a = −ω²x, the acceleration graph is the displacement graph turned upside down and scaled by ω².
- Velocity leads displacement by a quarter of a cycle, π/2 rad. Acceleration and displacement are in antiphase, a phase difference of π rad.
Sketching all three on one time axis and checking those three statements is the quickest way to catch an error.
17.2 Energy in simple harmonic motion
The interchange between kinetic and potential energy
In an undamped oscillator, energy passes back and forth between kinetic and potential energy, and the total stays constant. The potential energy is elastic for a mass on a spring and gravitational for a pendulum.
- At the extremes, x = ±x₀: the object is momentarily at rest, so the kinetic energy is zero and the potential energy is at its maximum, equal to the total.
- At equilibrium, x = 0: the speed is greatest, so the kinetic energy is at its maximum, equal to the total, and the potential energy is at its minimum.
- In between, kinetic energy is converted to potential energy as the object moves out, and back again as it returns, with the sum unchanged.
Total energy: E = ½mω²x₀²
The total energy equals the maximum kinetic energy, at equilibrium, where v = v₀ = ωx₀:
E = ½mv₀² = ½mω²x₀²
- E in J, m in kg, ω in rad s⁻¹, x₀ in m
The feature examined most often: E is proportional to the square of the amplitude. Doubling the amplitude gives four times the energy. E is also proportional to ω², so at the same amplitude a faster oscillator stores more energy.
At any displacement x, the kinetic energy follows from v = ω√(x₀² − x²):
E_k = ½mω²(x₀² − x²)
and the potential energy is the rest, E_p = ½mω²x². Against displacement, both are parabolas. Against time, each one rises and falls twice per cycle, so it varies at twice the frequency of the oscillation.
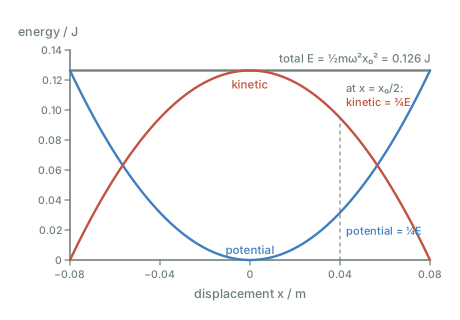
Worked example 6. A 0.25 kg mass oscillates with amplitude 0.080 m at a frequency of 2.0 Hz. Find (a) the total energy, (b) the kinetic energy at a displacement of 0.040 m, (c) the total energy if the amplitude is doubled.
ω = 2π × 2.0 = 12.57 rad s⁻¹
(a) E = ½mω²x₀² = 0.5 × 0.25 × 12.57² × 0.080² = 0.1264, so E = 0.126 J
(b) E_k = ½mω²(x₀² − x²) = 0.5 × 0.25 × 12.57² × (0.0064 − 0.0016) = 0.0948, so E_k = 0.095 J
That is three quarters of the total: at half the amplitude, the potential energy is only a quarter of the total, because it depends on x².
(c) E is proportional to x₀², so E = 4 × 0.1264 = 0.5056, about 0.51 J.
The trap in (b): assuming that halfway out means half the energy has become potential energy.
17.3 Damped and forced oscillations, resonance
Damping
A resistive force acting on an oscillating system, such as air resistance, friction or the drag of a liquid, does work against the motion. It removes energy from the oscillator, usually as thermal energy in the surroundings, so the amplitude decreases. This is damping.
Since E ∝ x₀², the energy falls even faster than the amplitude.
Light, critical and heavy damping
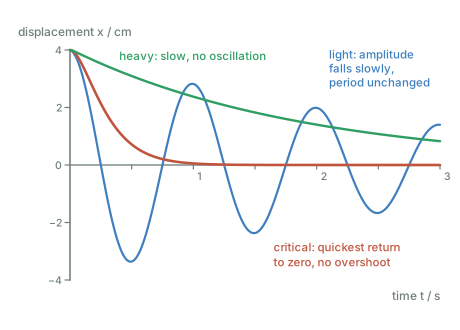
- Light damping. The system still oscillates, with an amplitude that decreases gradually. The period stays essentially the same as the undamped period. A pendulum swinging in air is lightly damped.
- Critical damping. The system returns to equilibrium in the shortest possible time without oscillating: it does not overshoot. Car suspension systems are designed to be close to critically damped, so the car settles quickly after a bump without bouncing.
- Heavy damping. The system returns to equilibrium without oscillating, but more slowly than with critical damping, because the large resistive force slows its approach. A door closer is heavily damped.
When sketching: light damping shows oscillations of decreasing amplitude with a constant period, crossing the time axis at equal intervals. Neither the critical nor the heavy curve crosses the axis, and the critical curve reaches zero first.
Forced oscillations
Every oscillating system has a natural frequency f₀, the frequency at which it oscillates freely when displaced and released. If a periodic driving force is applied, the system undergoes forced oscillations at the frequency of the driver, not at its own natural frequency.
Resonance
Resonance is a maximum amplitude of oscillation. It occurs when the system is forced to oscillate at its natural frequency, when the driving frequency equals f₀. At that frequency the driver transfers energy to the system most effectively, so the amplitude builds up until the energy lost to damping each cycle equals the energy supplied.
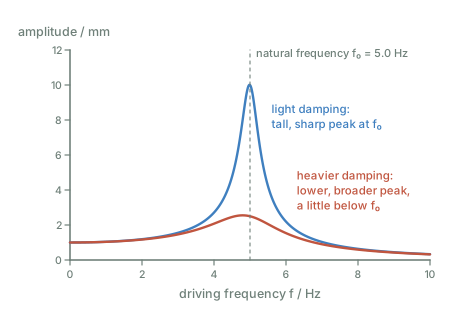
How damping changes the resonance curve, usually asked for as a set:
- the peak amplitude is lower
- the peak is broader (flatter)
- the peak moves to a slightly lower frequency
The amplitude away from resonance is hardly affected. The trap is drawing the damped curve above the lightly damped one, or crossing it at high frequency.
Resonance is useful in tuning a radio circuit, in a microwave oven (driving water molecules) and in musical instruments. It is harmful when wind, an earthquake or machinery drives a structure at its natural frequency: bridges, buildings and engine mountings are designed to have natural frequencies away from the likely driving frequencies, and damping is added to keep any resonant amplitude small.
Common mistakes
- Measuring the amplitude from one extreme to the other instead of from equilibrium.
- Defining SHM without "towards a fixed point" or "in the opposite direction", or dropping the minus sign from a = −ω²x.
- Saying the period depends on the amplitude.
- Leaving the calculator in degree mode when evaluating sin ωt or cos ωt.
- Using x = x₀ sin ωt when the object was released from maximum displacement, where x = x₀ cos ωt is needed.
- Forgetting the ± in v = ±ω√(x₀² − x²), or replacing √(x₀² − x²) by x₀ − x.
- Giving a phase difference as a fraction of a cycle rather than as an angle.
- Saying doubling the amplitude doubles the energy. It quadruples it.
- Saying the kinetic energy is greatest at the extremes. It is greatest at equilibrium.
- Drawing kinetic or potential energy against time with the same frequency as the displacement, instead of twice it.
- Drawing a critically damped curve that overshoots, or a heavily damped curve that reaches zero before the critical one.
- Saying resonance happens when the driving frequency is greater than the natural frequency. It happens when they are equal.
- Saying damping makes the resonance peak higher or sharper. It makes it lower and broader.
What the syllabus asks for on this topicSyllabus points
Syllabus points
17.1 Simple harmonic oscillations
- Understand and use the terms displacement, amplitude, period, frequency, angular frequency and phase difference in the context of oscillations, and express the period in terms of both frequency and angular frequency.
- Understand that simple harmonic motion occurs when acceleration is proportional to displacement from a fixed point and in the opposite direction.
- Use a = −ω²x and recall and use, as a solution to this equation, x = x₀ sin ωt.
- Use the equations v = v₀ cos ωt and v = ±ω√(x₀² − x²).
- Analyse and interpret graphical representations of the variations of displacement, velocity and acceleration for simple harmonic motion.
17.2 Energy in simple harmonic motion
- Describe the interchange between kinetic and potential energy during simple harmonic motion.
- Recall and use E = ½mω²x₀² for the total energy of a system undergoing simple harmonic motion.
17.3 Damped and forced oscillations, resonance
- Understand that a resistive force acting on an oscillating system causes damping.
- Understand and use the terms light, critical and heavy damping and sketch displacement-time graphs illustrating these types of damping.
- Understand that resonance involves a maximum amplitude of oscillations and that this occurs when an oscillating system is forced to oscillate at its natural frequency.
Related CIE 9702 Physics topics
Not the topic you were looking for? Describe what you are stuck on in your own words and we will take you to the notes that answer it.